Schneider Lexium 32 A320 Following Error: What to Check Before Replacing the Drive
Table of Contents
Schneider describes this error as excessive deviation between reference and actual position caused by the load. Its recommended starting points are external load and acceleration—not immediate drive replacement. A different drive rating may be necessary, but only after the application requirements have been reviewed.
The useful question is therefore: Where in the movement does the motor stop keeping up, and what changes at that moment?
The parameter examples below come from the Lexium 32C User Guide, 0198441113761, September 2017. Confirm the complete drive reference, firmware and operating mode before applying them to another Lexium 32 variant.
Capture the movement that produces A320
A photograph of the alarm helps identify the fault. A recording of the movement helps explain it.
Before resetting or changing settings, save the existing configuration and fault history. Note the active recipe, payload, direction of travel and whether the error occurred immediately after enabling, during acceleration or farther into the cycle.
Where the commissioning tools provide suitable recording functions, capture reference position, actual position and motor current on the same time base. Include the period before the trip. A trace that starts after the axis has stopped leaves out the part you need.
These patterns can guide the investigation; none identifies a failed component on its own.
| What happens before A320 | What to investigate next |
|---|---|
| Position deviation rises during a steep acceleration ramp | Whether the requested acceleration suits the load and available torque |
| Current rises while movement slows at the same physical location | Local resistance, interference, binding or a process load |
| The first movement after enabling fails, while later movements behave differently | Brake release, the enable sequence and differences in the commanded movement |
| The problem appears immediately after a recipe or configuration change | Acceleration, scaling, gearing and changed limits |
| Actual position oscillates around the reference | Mechanical looseness and control-loop behaviour before adjusting tuning |
Compare equivalent cycles. An empty machine moving slowly is a different test from a loaded production cycle.
- Related Product
Need a Replacement Altivar Drive?
Browse new original Altivar drives for maintenance, troubleshooting, and replacement projects.
- New original parts
- Fast response
- Global shipping
Separate a changed command from a changed machine
The history of the fault often narrows the search faster than the alarm number.
If the axis ran reliably until a recipe change, compare the old and new motion profiles. The final speed may be unchanged while the acceleration time has been shortened. That still changes the torque demand.
If the problem began after a drive replacement or parameter download, compare the configuration against the approved machine backup. Pay particular attention to position scaling, electronic gearing, motor configuration and limits. A drive that powers up without a configuration alarm has not yet proved that its motion settings match the machine.
A fault that developed on an otherwise unchanged machine deserves a different investigation. Look for increased resistance, altered belt tension, damaged bearings, contamination, changed tooling or a heavier product.
Illustrative example: An indexing axis starts tripping after the acceleration time is reduced for a faster cycle. Restoring the previously validated profile removes the fault. That makes the new motion demand a strong lead; it does not establish that the drive needs replacing.
A controlled reduction in acceleration can be informative, consistent with Schneider’s troubleshooting advice. Treat it as a diagnostic comparison, however, rather than proof that the original mechanical condition is acceptable. Schneider Electric: recommended A320 corrective actions
A brake command does not prove that the brake released
On a braked axis, distinguish the electrical command from the mechanical result.
Schneider explains that BSH and BMH motor brake delays are included in the motor’s electronic nameplate. The drive accounts for these delays, while BRK_AddT_release and BRK_AddT_apply provide additional release and application time. Power-stage enable and operation enable are therefore different points in the sequence. Schneider Electric: Lexium 32 brake operation
For diagnosis, establish whether the brake actually releases and whether the controller waits for the appropriate drive state. An output shown as ON in the PLC is not enough to settle either question.
A sticking brake or a problem in its supply circuit needs investigation at the brake and wiring. Adding delay cannot repair a brake that never releases.
Vertical axes need particular care. Secure the load independently before any procedure that could remove holding torque or release the brake. Electrical and mechanical checks should follow the machine’s isolation procedure and the applicable drive manual.
- PLC Solutions
Find the Right PLC for Your System
Explore new original PLC CPUs, I/O modules, power supplies, and communication units for maintenance and automation projects.
- New original parts
- Fast response
- Global shipping
Read the deviation limit before changing it
Two settings are easy to confuse:
MON_p_dif_loadsets the permitted load-dependent position deviation.ErrorResp_p_difselects the response to excessive deviation.
Changing the response does not reduce the underlying position error. Raising the limit allows a larger deviation before the fault occurs.
The 32C manual also provides MON_p_dif_load_usr in user-defined units; its values depend on scaling. Its documented monitoring scope includes Jog and Electronic Gear operation. These details matter when comparing settings between machines. Lexium 32C User Guide, pages 297–299
Before accepting a threshold change, relate it to the mechanism. How much linear travel or output rotation does the permitted motor-position error represent? Would that deviation already compromise registration, clearance or product quality?
A larger threshold may silence A320 while leaving the machine outside its acceptable positioning tolerance. Any change needs an engineering reason and a recorded validation result.
Leave tuning until the mechanics and command make sense
Tuning becomes a reasonable next step when the mechanism moves correctly, the brake releases, the command is appropriate and the configuration matches the application.
It is a poor starting point when the axis is binding.
Preserve the existing tuning values and compare traces before and after each controlled change. Changing gains, acceleration and the following-error threshold together may get the machine moving, but it makes the cause difficult to establish.
If autotuning is appropriate for the exact drive and machine, follow its commissioning procedure and provide the required safe movement space. Do not assume the machine can tolerate every movement a tuning routine requests.
Frequently Asked Questions
A320 identifies excessive following error; it does not specifically identify lost encoder communication. If feedback-related diagnostics also appear, investigate those using the applicable manual. Replacing an encoder cable solely because A320 is present skips the evidence needed to identify the cause.
Jogging may use a lower acceleration, lighter load or a different sequence. Compare those conditions before treating a successful jog as proof that the axis is healthy. On the documented Lexium 32C, following-error monitoring is available in Jog as well as Electronic Gear operation.
Only after confirming that the settings represent the same physical tolerance and suit the application. Matching numbers can be misleading when scaling or transmission ratios differ. The 32C manual specifically identifies scaling dependence for the user-unit parameter.
A factory reset is not a useful first diagnostic step. It changes the configuration you need to investigate and may remove application-specific settings. Save the existing configuration, compare it with an approved backup and establish the cause before deciding whether recommissioning is necessary.
No. That result makes the release sequence worth investigating, but it does not establish that the brake and its supply are healthy. Verify repeatable release under the required operating conditions. Schneider’s additional delay supplements the motor’s mechanical delay; it does not confirm physical brake movement.
Power your projects with brand-new, original Omron, Mitsubishi, Schneider Servo – in stock, ready now!
What evidence justifies replacing the drive?
A replacement decision should explain why the drive is the suspect.
Useful evidence could include a separate hardware diagnostic, manufacturer-supported test results, or service findings that isolate a fault inside the amplifier. A320 alone does not provide that isolation.
A capacity problem is a different purchasing decision. If the production requirement exceeds the validated capability of the axis, review the motor-drive combination, motion profile and mechanical transmission together. A larger amplifier alone is not a complete sizing assessment.
Before requesting a replacement, assemble:
- The complete drive and motor references.
- Supply details and the installed control interface.
- Firmware information and a parameter backup.
- Fault history and a recording of the failing movement.
- A short account of what changed and which checks were completed.
When a replacement enquiry is justified, send that information with clear nameplate photographs to Kwoco. It gives the enquiry a defined technical starting point instead of relying on “Lexium 32 with A320.”
After correcting the cause, use the reset procedure for the installed variant. For the documented 32C procedure, the manual requires the cause to be remedied before reset.
The final acceptance test should reproduce the conditions that previously caused the trip, within a controlled commissioning procedure. Record the resulting deviation and current alongside the final settings. A cleared display is only the beginning of that test.
Contact Us
Just fill out your name, email address, and a brief description of your inquiry in this form. We will contact you within 24 hours.
Product Category
Hot Sale Products
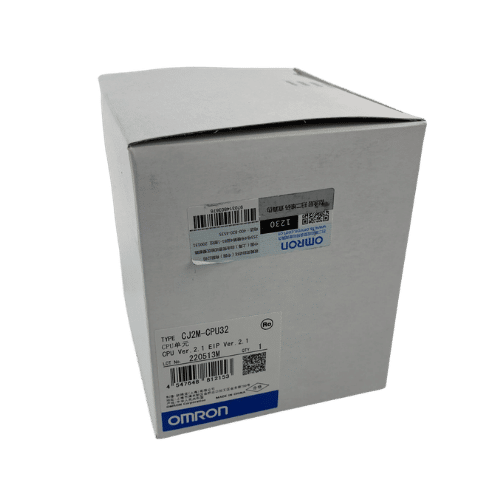
Omron CPU Unit CJ2M-CPU32
Omron PLC CJ1W-PA202 Supplier in China
Mitsubishi MR-JE Series 400w Servo Drive MR-JE-40A
Need a Fast Match?
Share your model or spec and our team will help you find the right fit-fast.
- Expert support
- Quick response
- Competitive price
- +86-755-81481609
- [email protected]
You May Also Find These Topics Interesting
France Omron PLC Supplier Near You
In the field of industrial automation, integrity and effectiveness are the foundations of success. As the core of complex systems, the PLC
Contactor vs Relay: Understanding the Difference Between Contactors and Relays
This article dives deep into the world of contactors and relays, two essential components in industrial automation and control systems. We’ll explore their
Everything You Need to Know About Pneumatic System Components
This article provides a comprehensive overview of pneumatic systems, a critical technology in industrial automation. We will delve into the intricacies of